Designing Cable Harnesses for Robotic Motion
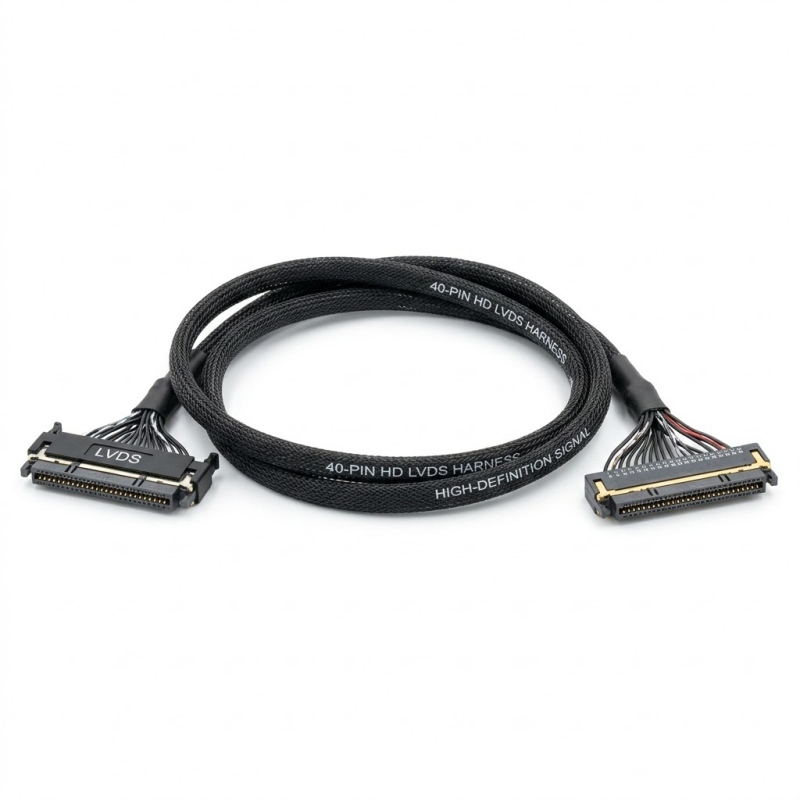
A cable harness designed for a fixed installation may fail quickly when placed in continuous motion. Robotic applications need a defined bend radius, controlled routing path, suitable jacket construction and strain relief that prevents excessive load at the connector.
The motion profile should be described in terms of travel, speed, cycle frequency, torsion and environmental exposure. Prototype testing under representative routing conditions is an important step before volume release.
WELLXEN supports custom robotic harness development for articulated equipment, AGVs, machine vision systems and automated production lines.